 Mobile Manipulator
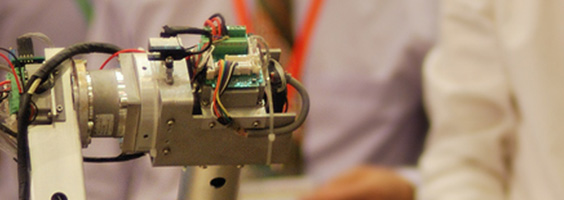
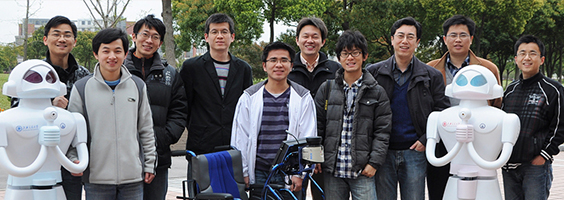
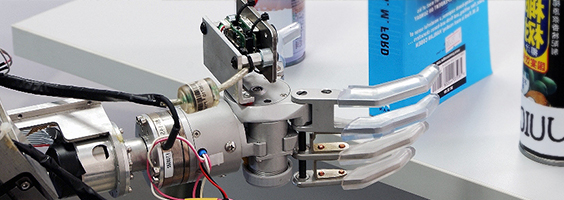
We are doing research on automatic operation of mobile manipulator in structured or unstructured environment, for the purpose of providing theoretical basis and practical experience in real applications. The main study including:
localization, mapping, trajectory planning and motion control of the mobile base.
manipulator automatic operation combining with computer vision, including goods transport, component assembly, insertion and extraction of plugs, etc.
task planning and motion planning of the whole mobile manipulator.
The current progress:
obstacle avoidance motion planning of the manipulator

motion control of the omni-mobile base

part assembly based on computer vision


RJ45 connector insertion and extraction based on computer vision